All projects
Case Study03 / 05
Vision-Based Palletizing with MoveIt Task Constructor
Product recognition with YOLO, sorting logic, and collision-aware pick-and-place planned with MoveIt Task Constructor.
ROS 2
MoveIt 2
YOLO
Gazebo
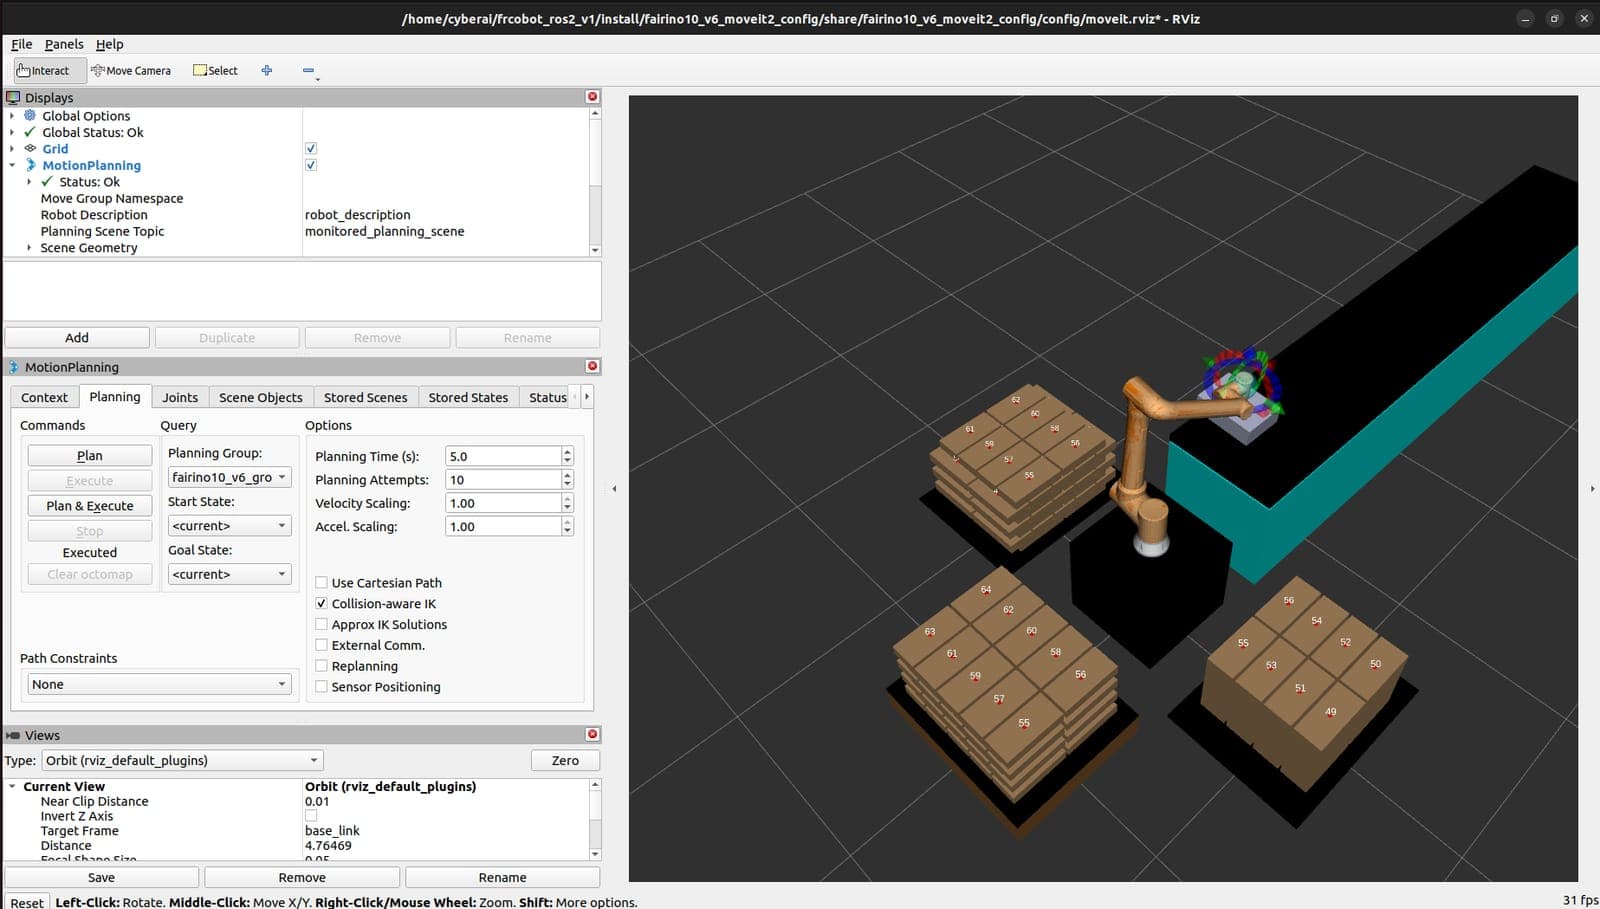
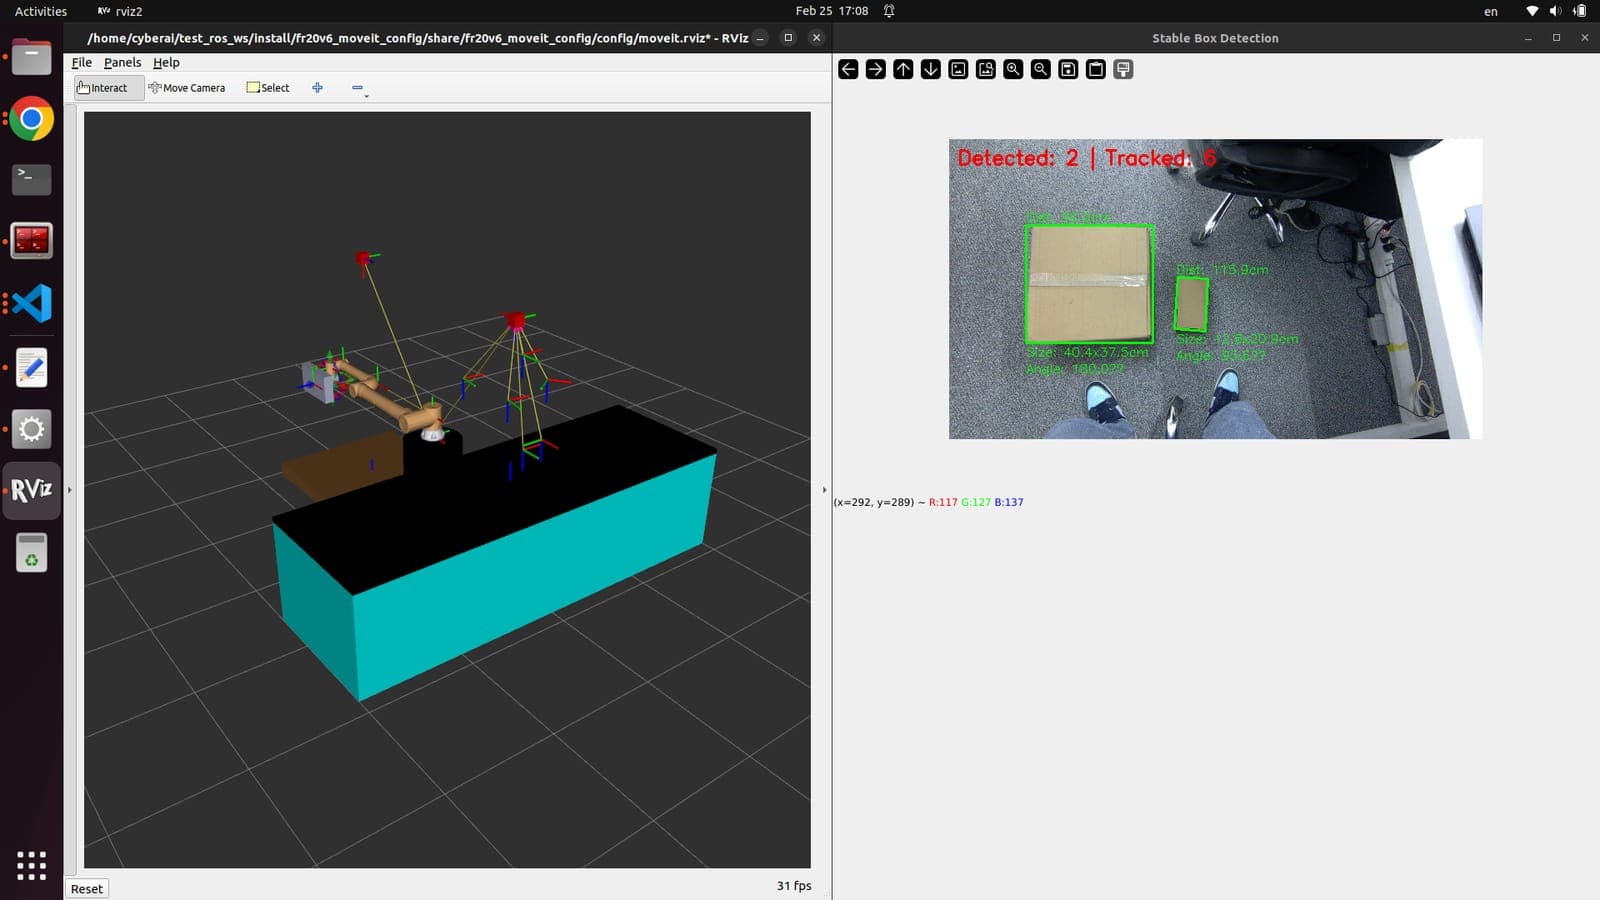
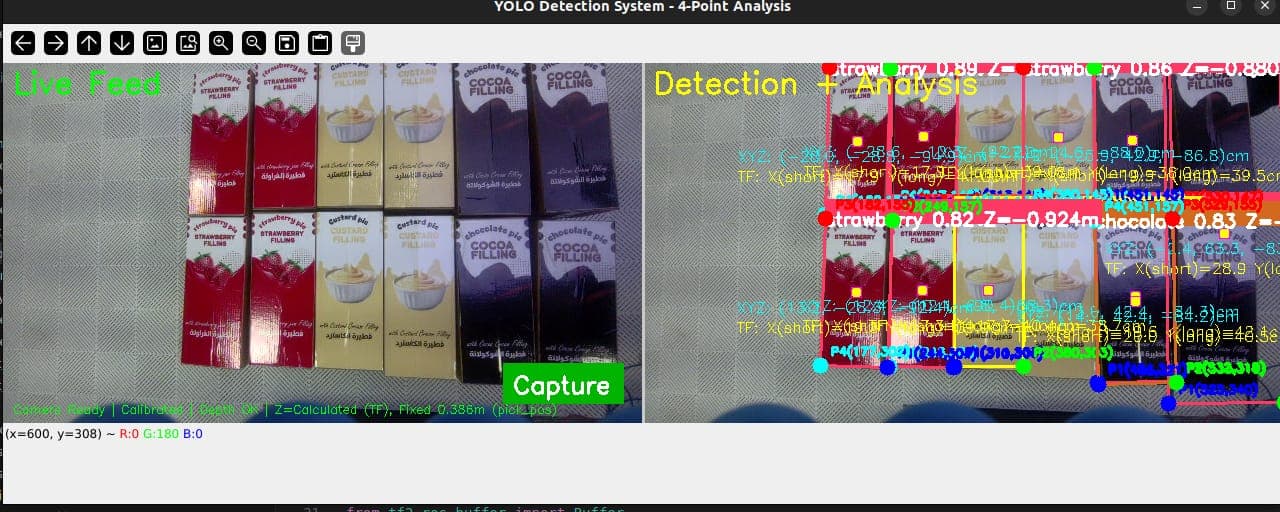
01 · Problem
Manual palletizing is labor-intensive and error-prone. The client needed automated product recognition and intelligent sorting with collision-free motion planning.
02 · My Role
- Converted the palletizing algorithms into ROS 2 and MoveIt 2 code.
- Trained YOLO on the products and turned detections into robot paths.
- Added per-pallet feedback to keep errors from accumulating.
03 · Solution
- Palletizing algorithms are translated into ROS 2 code that drives the robot.
- A YOLO model trained on the products turns each detection into a robot path for placing it on the pallet.
- Feedback after every pallet stops errors from building up.
04 · Stack
ROS 2
MoveIt 2 + MTC
YOLO (custom dataset)
Gazebo
Palletizing algorithms
Closed-loop feedback
05 · Results
Reliable product recognition and automated palletizing with collision-free motion. The system handles multiple product categories with intelligent sorting.
06 · Challenges
Training YOLO on a custom product dataset required careful annotation and augmentation. MoveIt Task Constructor's API is complex — building reliable pick-and-place sub-trajectories needed extensive testing in simulation before real-world deployment.
Have a similar project in mind? Let's talk.
mohammadkhalefa04@gmail.com