All projects
Case Study02 / 05
AI-Guided Robotic Welding (ROS 2)
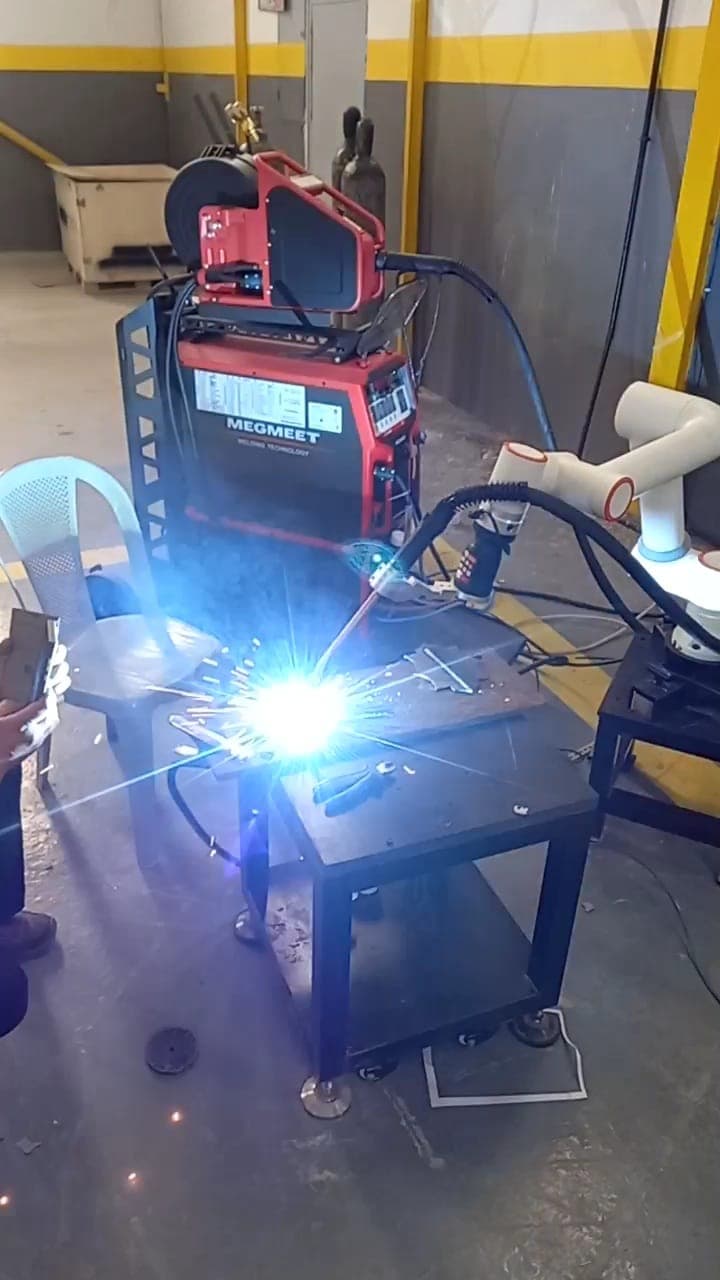
A welding cell where a trained model identifies the metal and seam, and recommends the path and weld settings.
ROS 2
MoveIt 2
YOLO
Welding
01 · Problem
Manual welding setup is slow and inconsistent. The client needed a system that could identify the workpiece and suggest optimal weld parameters automatically.
02 · My Role
- Planned the robot motions with ROS 2 and MoveIt 2.
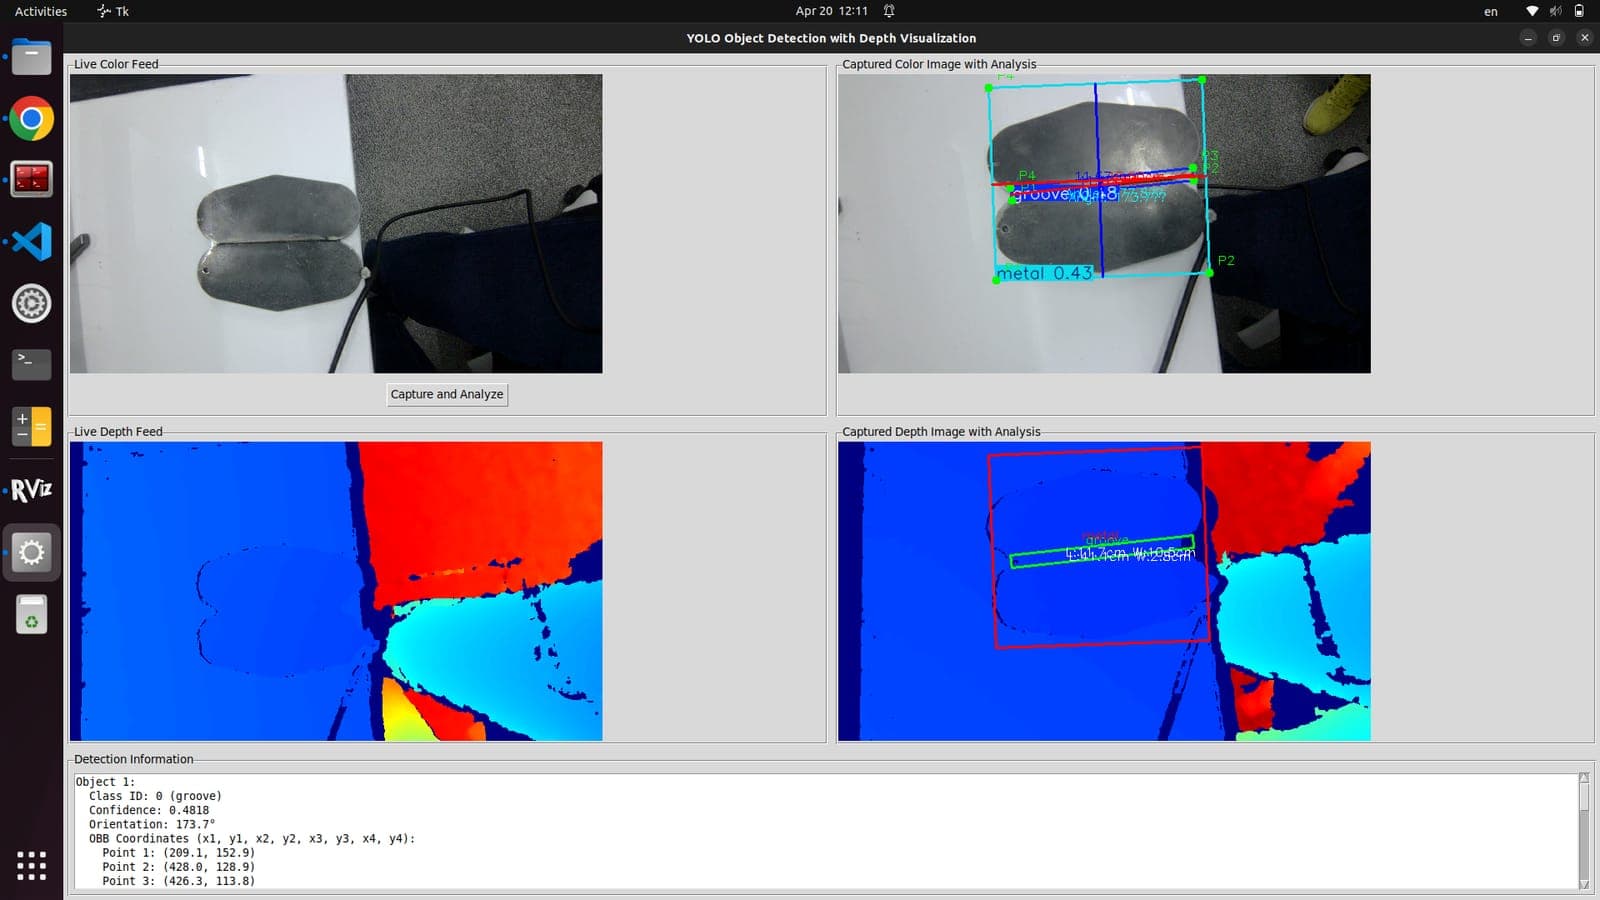
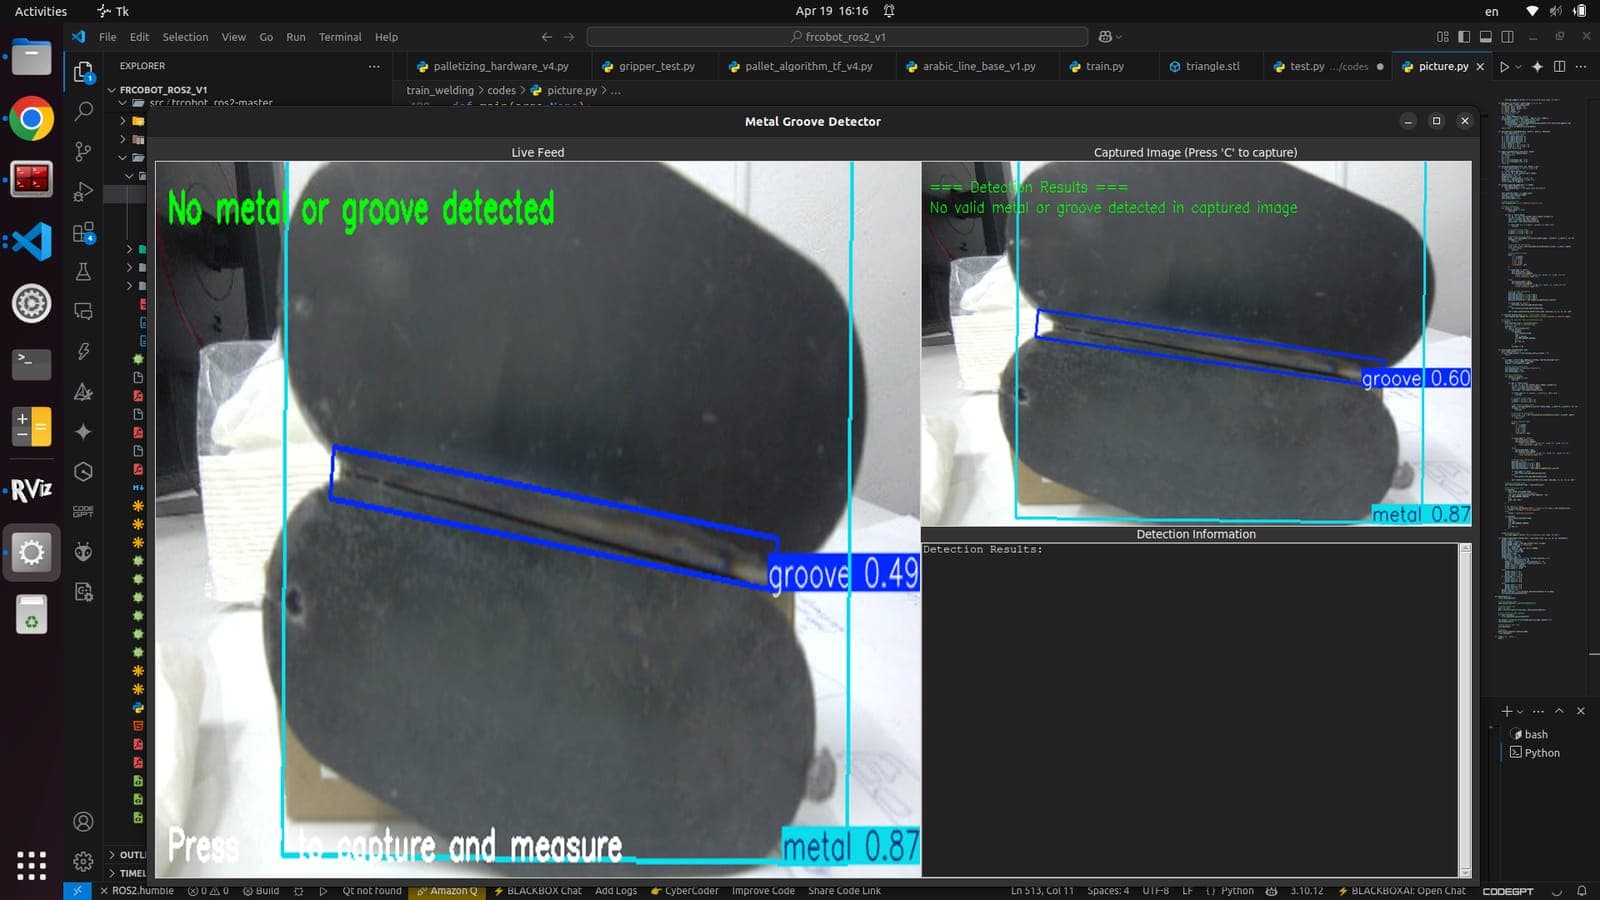
- Trained a YOLO model to recognise the metal and locate the weld positions.
- Integrated the 3D camera to detect the weld, generated the path and built the full pipeline.
03 · Solution
- The robot recognises the metal workpiece and finds the weld locations automatically, with suggested welding settings.
- A 3D camera is integrated to detect the weld seam and generate the robot path.
- One pipeline runs from detection to a planned, ready-to-weld path.
04 · Stack
ROS 2
MoveIt 2
YOLO
OpenCV
3D camera
Path planning
Operator UI
05 · Results
Reduced setup time per workpiece and improved consistency of weld seam detection. The operator UI enables human-in-the-loop verification before every weld.
06 · Challenges
Welding environments are harsh for vision systems — smoke, sparks, and reflective metal surfaces. The model needed robust training data and real-time inference at the edge. Integrating AI suggestions with MoveIt 2 motion planning required careful coordinate frame management.
Have a similar project in mind? Let's talk.
mohammadkhalefa04@gmail.com