Dual-Robot Cinematic Portrait & Drawing Cell
Two Fairino arms working as one system — one films people cinematically, the other draws their portrait in Ghibli style.
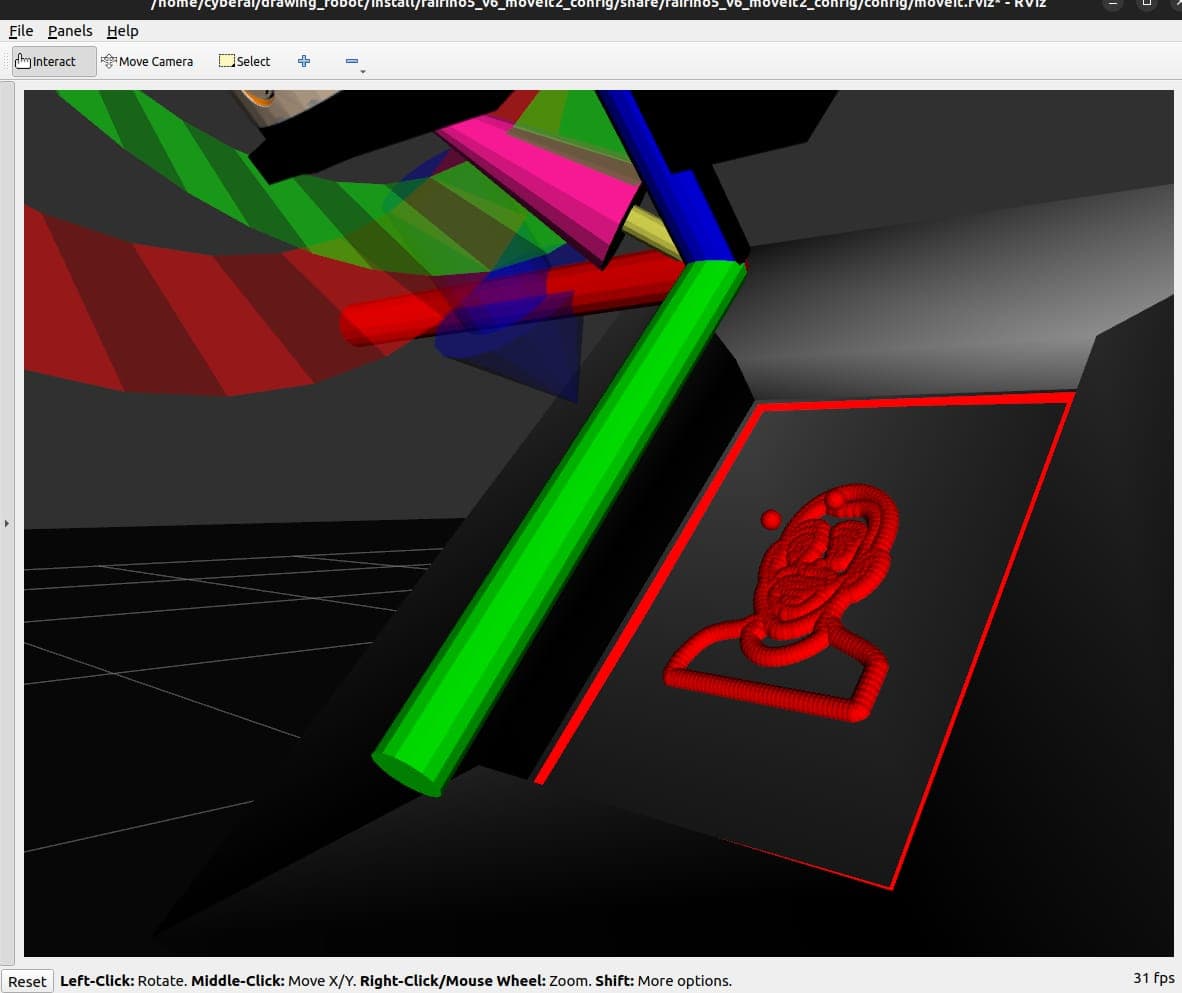
The client wanted an interactive robot experience that is safe around the public and produces a take-home artwork.
- Everything ROS 2 for the motion of both robots: MoveIt 2 motion planning on the Fairino SDK.
- Built the AI that recognises people (YOLO and OpenCV with the 3D camera).
- Automated the media pipeline: video editing, upload to Google Drive and QR code generation.
- Two robots work as one cell: one films guests cinematically, the other draws their portrait.
- AI on a 3D camera recognises people, the areas where filming is allowed and where it isn't, and groups people by height.
- The filming robot plans cinematic camera moves and controls a Canon camera through the Canon SDK.
- Each guest's video is edited automatically, uploaded to Google Drive and shared through a generated QR code.
Deployed at a live event with public interaction. Each guest received a cinematic video, a Ghibli-style portrait drawing, and a QR code to access their media.
Ensuring public safety required real-time person tracking with dynamic safety stops. Synchronizing two independent robot arms with different kinematics and SDKs needed a robust inter-robot communication layer. The image-to-path pipeline had to produce drawable paths within a reasonable time while maintaining artistic quality.
Have a similar project in mind? Let's talk.
mohammadkhalefa04@gmail.com